Maker project
omnidirectional-manipulator-ros2
BOM011868 · Omni-wheels-PCB
What the project is · as the catalogue files it; the circuit functions below are BOM rule hits
Filed under “智能硬件” in the ezPLM catalogue.
Circuit functions included · BOM rule hits · not reviewed
- Wireless SoC / wireless module
- U3 ESP32S_38P · by part number
- Wi-Fi
- U3 ESP32S_38P · by part number
- Bluetooth / Bluetooth Low Energy
- U3 ESP32S_38P · by part number
- Brushed DC motor driver
- U1, U2 L293D · by part number
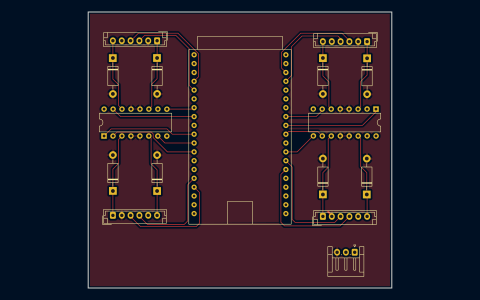
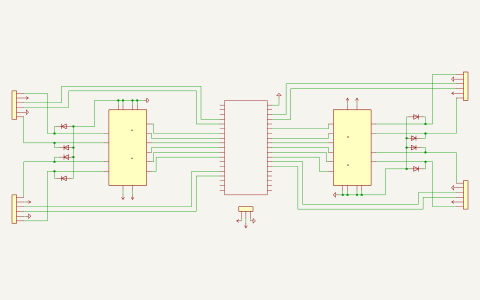
Online view
Loading the project view…
8 rows · 16 parts0 of 8 rows placedHover or click a row to mark its parts in the view; click a part in the view to find its row.
Looks up part numbers and makers at ezPLM, DigiKey and Mouser. What it finds are suggestions: check one before you use it.
| Designators | Value | Part | Qty | Placed | |
|---|---|---|---|---|---|
| D1, D2, D3, D4, D5, D6, D7, D8 | 1N4001D_DO-41_SOD81_P10.16mm_Horizontal | No part number | 8 | ||
| U1, U2 | L293DDIP-16_W7.62mm | No part number | 2 | ||
| U3 | ESP32S_38PESP32S_38P | No part number | 1 | ||
| J1 | Motor_1Interface labelJST_EH_B6B-EH-A_1x06_P2.50mm_Vertical | No part number | 1 | ||
| J2 | Motor_2Interface labelJST_EH_B6B-EH-A_1x06_P2.50mm_Vertical | No part number | 1 | ||
| J3 | Motor_3Interface labelJST_EH_B6B-EH-A_1x06_P2.50mm_Vertical | No part number | 1 | ||
| J4 | Motor_4Interface labelJST_EH_B6B-EH-A_1x06_P2.50mm_Vertical | No part number | 1 | ||
| J5 | Conn_01x03JST_EH_S3B-EH_1x03_P2.50mm_Horizontal | No part number | 1 |